© 2025 Messer Cutting Systems, Inc.
Choosing the best Omni Directional Wheel in 2026 requires more than comparing load ratings or asking for the lowest price. Modern mobile robots operate in tighter spaces, carry heavier payloads, and demand smoother lateral movement. The choice affects positioning accuracy, battery use, maintenance, and operator safety.
The International Federation of Robotics reported 541,302 industrial robots were installed worldwide in 2023. This figure shows how quickly automated equipment is entering factories and logistics facilities. Deloitte’s 2024 Smart Manufacturing and Operations Survey also found that 86% of manufacturing leaders expect smart manufacturing to become a major competitiveness driver within five years. These trends increase demand for reliable mobility components, including Omni Directional Wheel systems.
A practical evaluation should begin with real operating conditions. Measure the payload, wheel diameter, floor joints, turning space, travel speed, and duty cycle. A small warehouse robot may need quiet polyurethane rollers and precise control. A heavier platform may require steel components, sealed bearings, and stronger impact resistance. Check the wheel’s load distribution, not only its advertised maximum load. That number can change sharply on uneven floors.
Do not trust a catalog alone. Test the wheel on the actual surface, with the intended payload and controller. Observe vibration near corners, roller wear after repeated lateral movement, and stopping behavior on dust-covered flooring. Some specifications look impressive but lack long-term field evidence. That is where this guide may be imperfect, too. Real installations often expose details that laboratory testing misses. By combining manufacturer data, independent reports, and hands-on trials, buyers can select an Omni Directional Wheel with greater confidence in 2026.
How to Choose the Best Omni Directional Wheel in 2026?
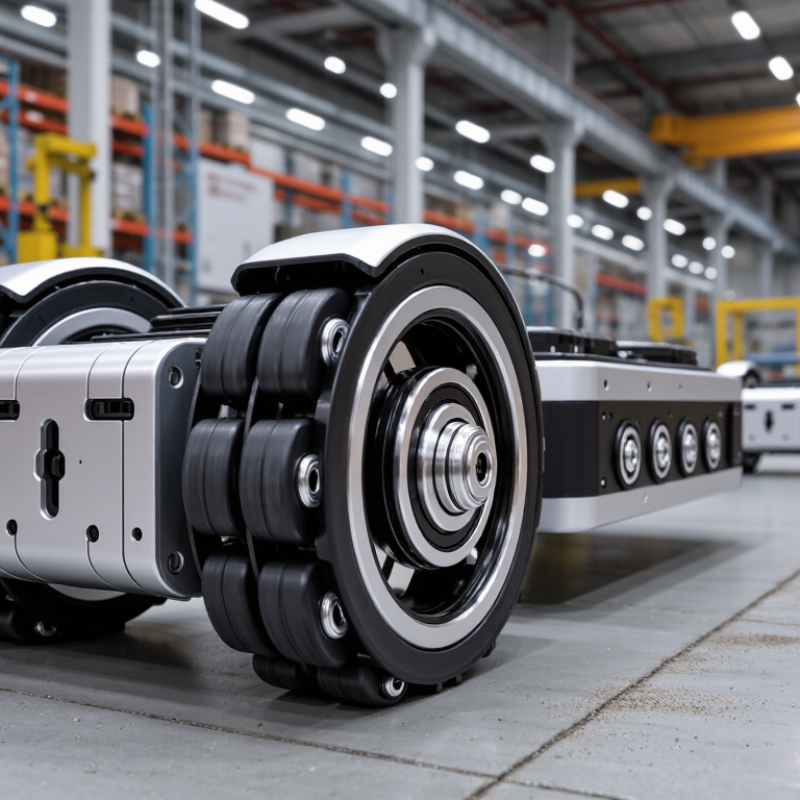
An omnidirectional wheel uses small rollers mounted around its rim. Each roller turns on its own axis, allowing movement forward, sideways, and diagonally. A robot can rotate while translating across a warehouse floor. This is called holonomic motion. The effect feels almost effortless, but control software must coordinate every wheel precisely.
The International Federation of Robotics reported 541,302 industrial robots were installed worldwide in 2023. That figure shows continued demand for compact, flexible mobile platforms. However, wheel selection remains practical rather than fashionable. Start with the required load, wheel diameter, roller spacing, and floor condition. Larger wheels cross cable covers more smoothly. Softer rollers reduce vibration but may wear faster. Hard rollers can carry more weight, yet they often slip on dusty concrete. A 2024 ISO 9283-based performance test should also examine positioning accuracy, repeatability, and drift. Real floors are rarely perfect. This is where specifications can disappoint.
Tips: Test the wheel under its actual load, not an empty chassis. Measure sideways speed, turning noise, and stopping distance. Check the smallest obstacle it can cross. Leave a safety margin above the rated load. Also inspect roller gaps; trapped debris can interrupt contact and create sudden motion. A 24-hour endurance trial is useful, though it may still miss seasonal temperature changes. The best choice is not always the wheel with the highest capacity. It is the wheel that stays predictable on your floor.
An omni directional wheel uses rollers mounted around its circumference, allowing a vehicle or platform to move forward, sideways, diagonally, or rotate by combining the speeds and directions of multiple independently driven wheels. The figures below are typical engineering ranges rather than brand-specific specifications.
| Selection Dimension | Typical Data or Range | What It Means | Recommended Choice | Why It Matters |
|---|---|---|---|---|
| Wheel Type | Standard Omni Wheel, mecanum wheel, or ball-style omni wheel | Standard omni wheels usually have rollers arranged around the wheel axis. Mecanum wheels use angled rollers, commonly at approximately 45 degrees. | Match the drive system | A standard omni-wheel layout and a mecanum layout require different wheel orientations, control algorithms, and chassis geometry. |
| Wheel Diameter | 50–200 mm for compact mobile platforms; larger sizes are available for heavier equipment | Larger wheels generally provide better obstacle clearance and lower rolling resistance, but they require more torque and installation space. | Choose the smallest diameter that safely clears floor joints, cables, and obstacles. | Diameter affects ground clearance, speed, torque demand, vibration, and the overall platform height. |
| Rated Load Capacity | Approximately 10–300 kg per wheel for many light- and medium-duty applications | Rated capacity is normally specified per wheel under defined loading and floor conditions. | Select a wheel rating at least 25–30% above the calculated maximum static load per wheel. | Uneven load distribution, acceleration, turning, floor gaps, and impacts can increase the actual force on individual wheels. |
| Load Calculation | Minimum target capacity = total system mass × safety factor ÷ number of load-bearing wheels | The total system mass should include the frame, battery, payload, electronics, and accessories. | Use a safety factor of about 1.25–1.50 for smooth indoor floors; use a higher factor for impacts or uneven floors. | Using only the nominal payload can lead to premature roller wear, motor overload, and unstable motion. |
| Roller Material | Polyurethane, rubber, nylon, or other engineered polymers | Polyurethane and rubber typically offer better grip and quieter operation. Nylon can provide low rolling resistance and good wear resistance on suitable floors. | Choose based on traction, noise, floor protection, chemical exposure, and expected wear. | Roller hardness and surface material strongly influence acceleration, stopping distance, vibration, and floor marking. |
| Roller Hardness | Common elastomer roller hardness is approximately 70–95 Shore A; exact values vary by compound | Softer rollers improve grip and shock absorption, while harder rollers generally reduce deformation and rolling resistance. | Use medium-hard rollers for general indoor floors; choose softer rollers where traction and floor protection are priorities. | Hardness must be balanced with load, speed, floor condition, noise limits, and required maneuverability. |
| Number of Rollers | Often 8–16 rollers per wheel, depending on wheel diameter and load rating | More rollers can reduce vibration and load variation, while fewer rollers may reduce cost and rolling contact points. | Choose a roller count that provides smooth contact without restricting free roller rotation. | Roller spacing affects ride smoothness, vibration, contact stability, and the ability to cross small floor irregularities. |
| Roller Rotation | Free-rotating rollers positioned around the wheel circumference | The main wheel rotation produces traction in one direction, while the rollers allow controlled lateral movement with reduced resistance. | Verify that each roller turns freely and has minimal axial play. | Sticking, damaged, or contaminated rollers can cause wheel scrub, inaccurate motion, noise, and increased motor current. |
| Drive Configuration | Common layouts include 3-wheel, 4-wheel, and multi-wheel independent-drive platforms | Each driven wheel must be controlled at the correct speed and direction to create the desired platform velocity. | Use a controller that supports independent wheel-speed control and calibrated kinematics. | Omnidirectional motion depends on coordinated wheel velocities rather than on the wheel alone. |
| Movement Capability | Forward, reverse, lateral, diagonal, and in-place rotation | These motions are generated by superimposing the longitudinal and lateral force components from multiple wheels. | Confirm that the selected wheel arrangement supports the required motion profile. | A wheel may be mechanically omnidirectional, but the complete platform may not achieve every direction without the correct geometry and control system. |
| Operating Speed | Common indoor platforms operate at approximately 0.5–2.0 m/s; the allowable speed depends on wheel design and load | Maximum speed is limited by wheel balance, roller design, motor speed, floor condition, payload stability, and control response. | Choose a wheel with a rated speed above the target operating speed, including a practical margin. | High speed can increase vibration, roller impact, stopping distance, and control error. |
| Floor Compatibility | Best on smooth, hard, level surfaces such as sealed concrete, epoxy, tile, and finished industrial flooring | Small rollers are sensitive to deep joints, loose debris, soft flooring, thresholds, and uneven surfaces. | Use larger wheels or a different wheel technology for rough floors, outdoor terrain, or frequent thresholds. | Floor quality directly affects traction, noise, energy consumption, and the accuracy of lateral movement. |
| Obstacle and Gap Capability | Typically limited to small gaps and low obstacles; practical capability depends on roller diameter and wheel design | Omni wheels are not intended to replace large pneumatic or solid wheels for significant obstacles. | Measure the largest floor gap and obstacle before selecting the wheel diameter. | Small rollers can drop into gaps or strike edges, causing shock loads, loss of traction, and premature damage. |
| Traction and Slip | Lower than conventional wheels during some lateral or diagonal movements | Because rollers must rotate, part of the drive force can be lost through roller contact and surface slip. | Use suitable roller material, correct wheel loading, and closed-loop speed control. | Slip reduces positioning accuracy and can increase energy consumption, especially during fast lateral acceleration. |
| Motor and Torque Requirement | Depends on total mass, acceleration, slope, wheel radius, rolling resistance, and desired speed | Torque must overcome rolling resistance and provide the required acceleration without exceeding the motor or gearbox limits. | Size the motor using peak torque, continuous torque, thermal limits, and battery voltage—not only rated power. | Under-sized drive components can cause overheating, slow response, stalling, and uneven motion between wheels. |
| Precision and Control | Best results require wheel encoders, calibrated wheel spacing, and closed-loop control | Encoder feedback helps regulate wheel speed and compensate for load changes and moderate slip. | Use encoder feedback and periodic calibration for positioning-sensitive applications. | Mechanical tolerances, roller wear, unequal loading, and floor friction can otherwise create heading and position errors. |
| Turning and Rotation | In-place rotation is possible when wheel forces are balanced around the platform center | The controller commands different wheel velocities so the net force creates angular motion. | Confirm that the platform center of rotation and wheel spacing are included in the motion model. | Incorrect geometry or unequal wheel friction can cause the platform to drift during rotation. |
| Noise and Vibration | Usually higher than conventional wheels on rough floors or across joints | Individual rollers repeatedly enter and leave contact with the floor, producing periodic vibration. | Choose balanced wheels, suitable roller materials, and a smooth floor route. | Noise and vibration can affect sensors, payloads, operator comfort, and mechanical service life. |
| Maintenance Requirements | Regular inspection of roller rotation, bearings, fasteners, debris, wear, and alignment | Rollers and bearings are exposed to dust, hair, chips, and impact from floor irregularities. | Select replaceable rollers and accessible bearings for frequent-use equipment. | Preventive maintenance helps preserve traction, reduce noise, and maintain consistent motion accuracy. |
| Best Application Fit | Indoor robots, material-handling platforms, inspection equipment, service carts, and automated workstations | These applications typically provide smooth floors and require compact maneuvering in limited spaces. | Choose omni wheels when lateral movement and a tight turning radius are more important than rough-terrain performance. | Omnidirectional mobility can reduce aisle width and simplify positioning, but it requires more sophisticated control than a conventional wheel layout. |
| When Not to Use | Rough outdoor terrain, deep floor gaps, loose gravel, soft ground, steep slopes, or very high shock loads | Small rollers can lose contact, become damaged, or generate excessive vibration in these environments. | Consider conventional, tracked, pneumatic, or other terrain-specific mobility solutions. | The best wheel is determined by the complete operating environment, not by load capacity alone. |